|
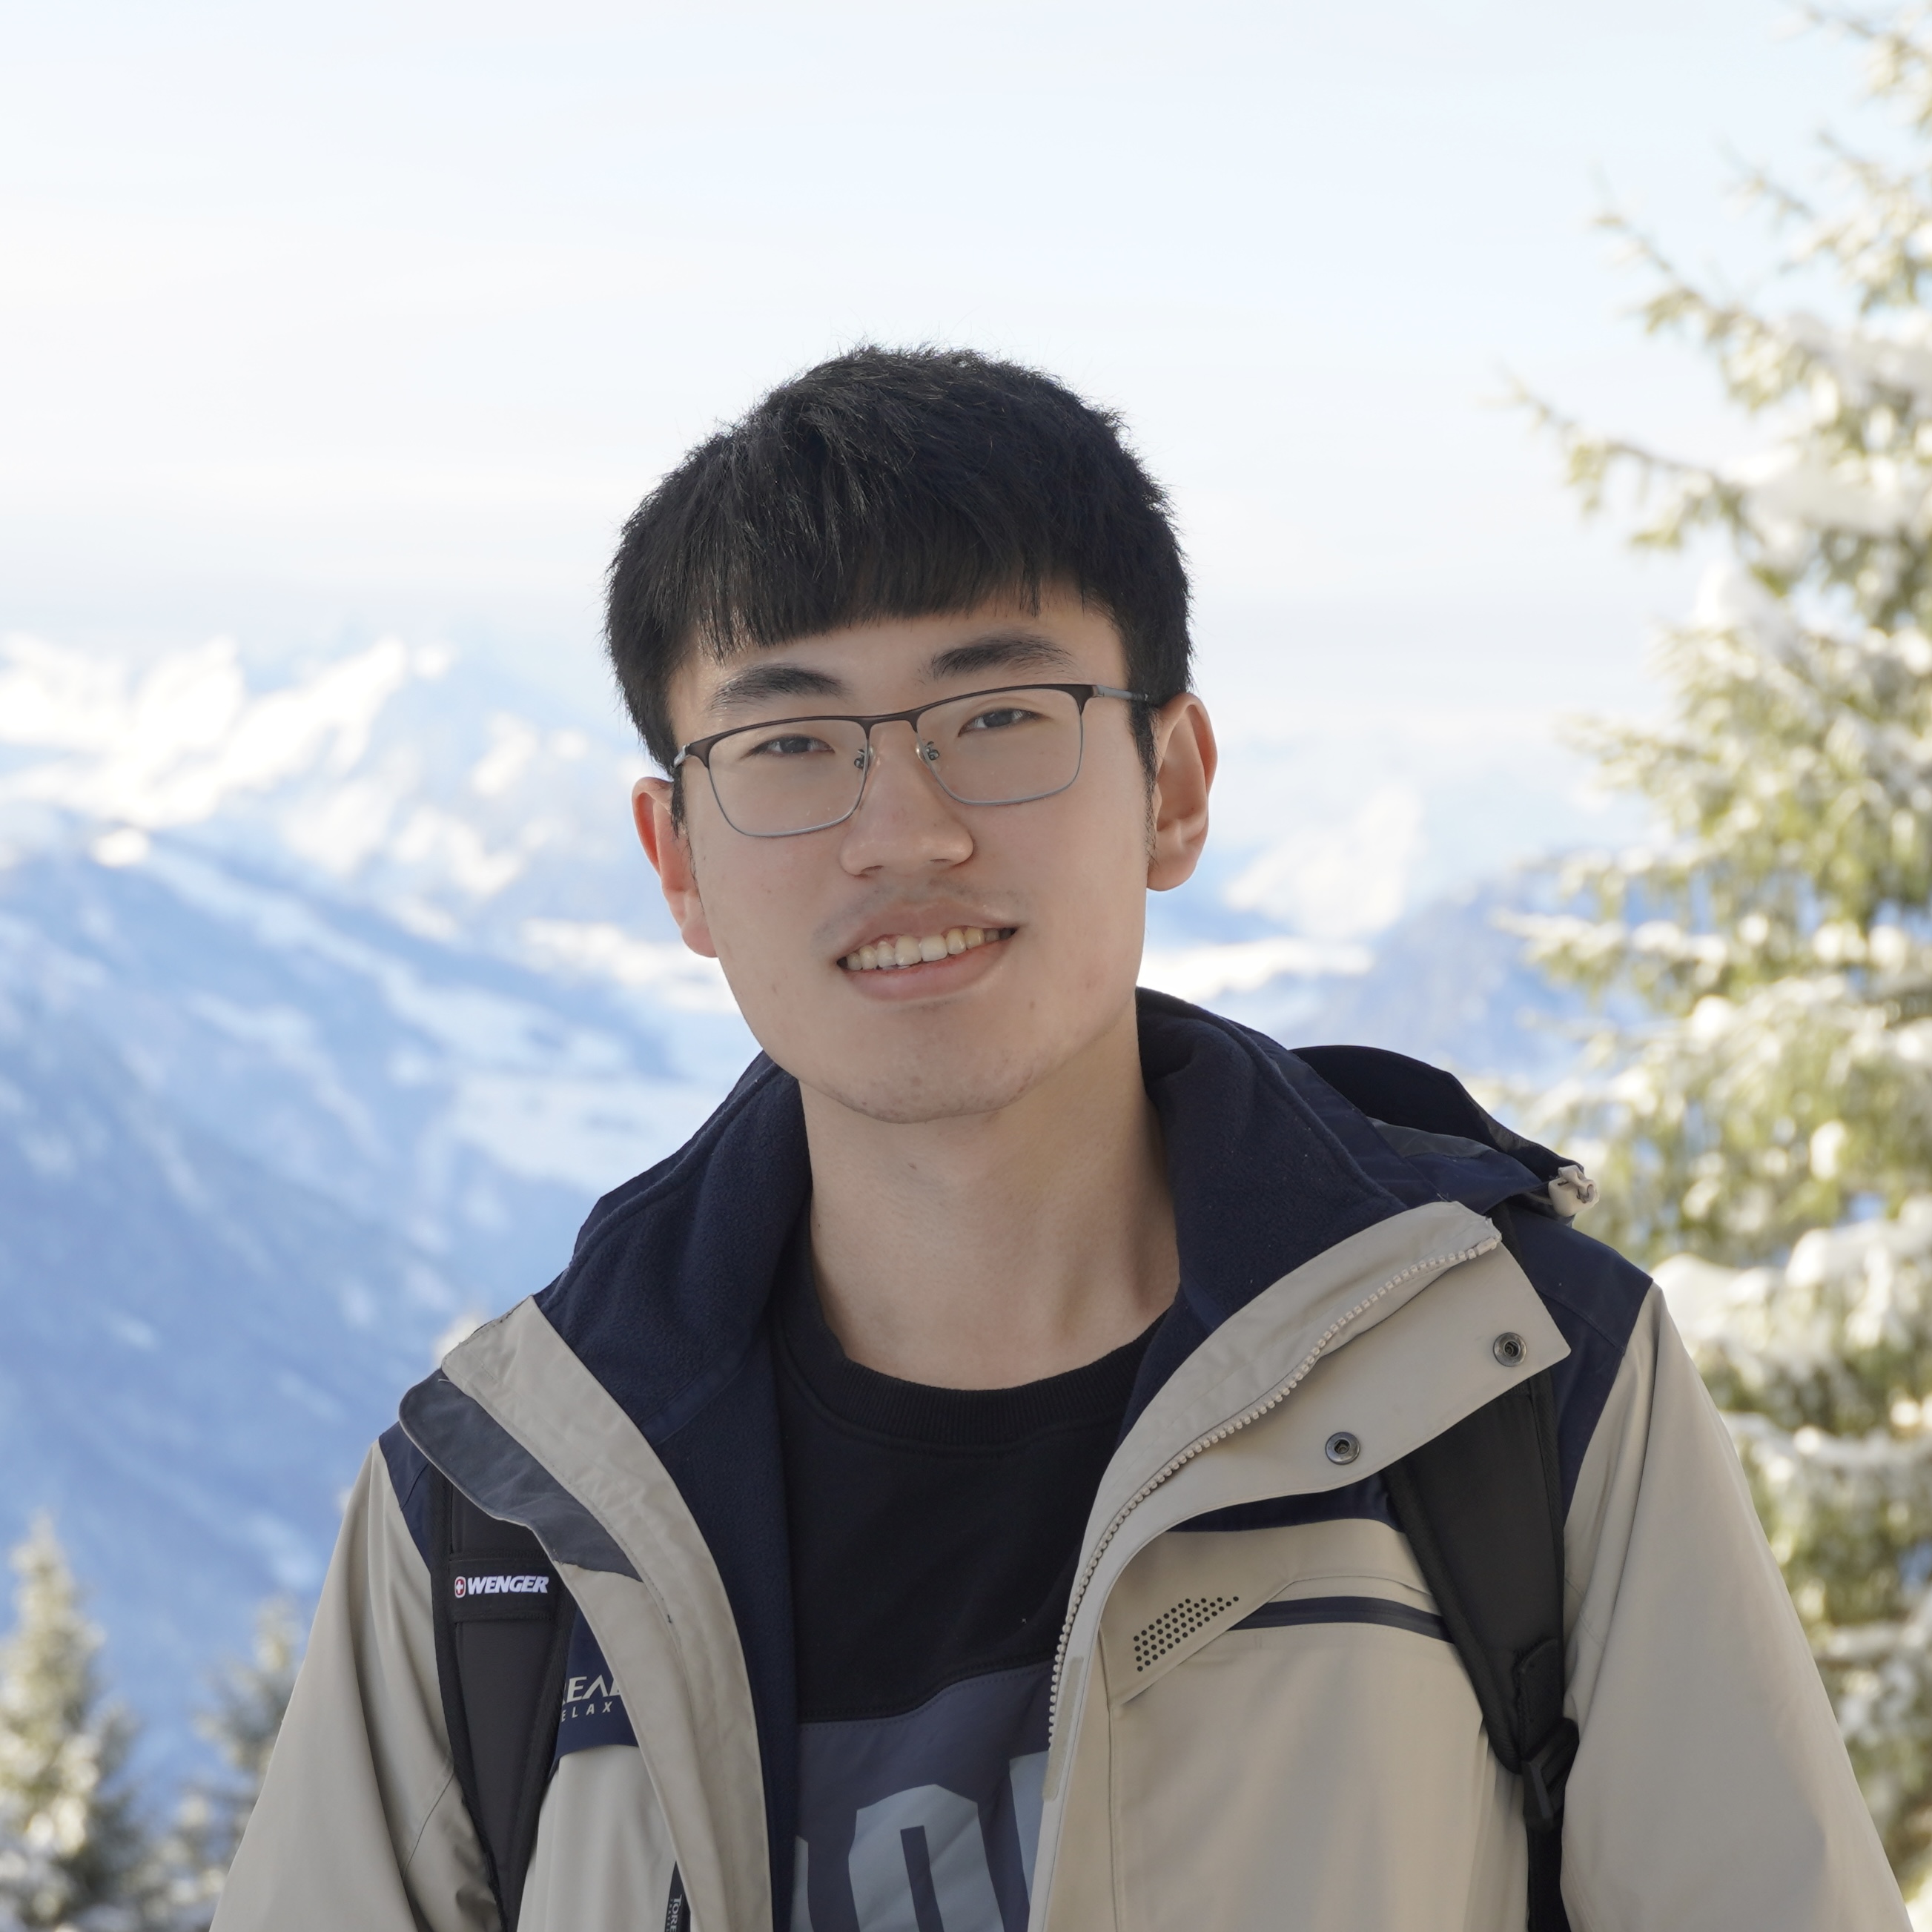
Jialin Li 李嘉麟 I am a Ph.D. student affiliated with the MechSE Department at University of Illinois Urbana-Champaign, advised by Prof. Naira Hovakimyan. I received my M.S. degree in Robotics, Systems, and Control with distinction from ETH Zurich in 2024, where I finished my master's thesis on Time-Varying Safe Bayesian Optimization at the Automatic Control Laboratory, advised by Prof. Dr. John Lygeros. Before that, I obtained my B.S. degree in Theoretical and Applied Mechanics with summa cum laude from University of Science and Technology of China in 2021. I interned at Bosch Center for Artificial Intelligence (BCAI) in Renningen, Germany in 2024. |
|
ResearchWill passive but massive data collection, which has come to dominate robotics, eventually give rise to a virtuous cycle in which widely deployed robots feed their experience back into the models that drive them? Perhaps. But even if that cycle closes, would we have built an intelligence with the metacognition to know what it does not know and what it needs to know? These questions drive my research on enabling robots to 1) autonomously select high-value data from the overwhelming stream they gather, and 2) continuously learn from actively acquired experiences, safely and at scale, with the goal of advancing generalist robots and intelligence. |
Publications |
|
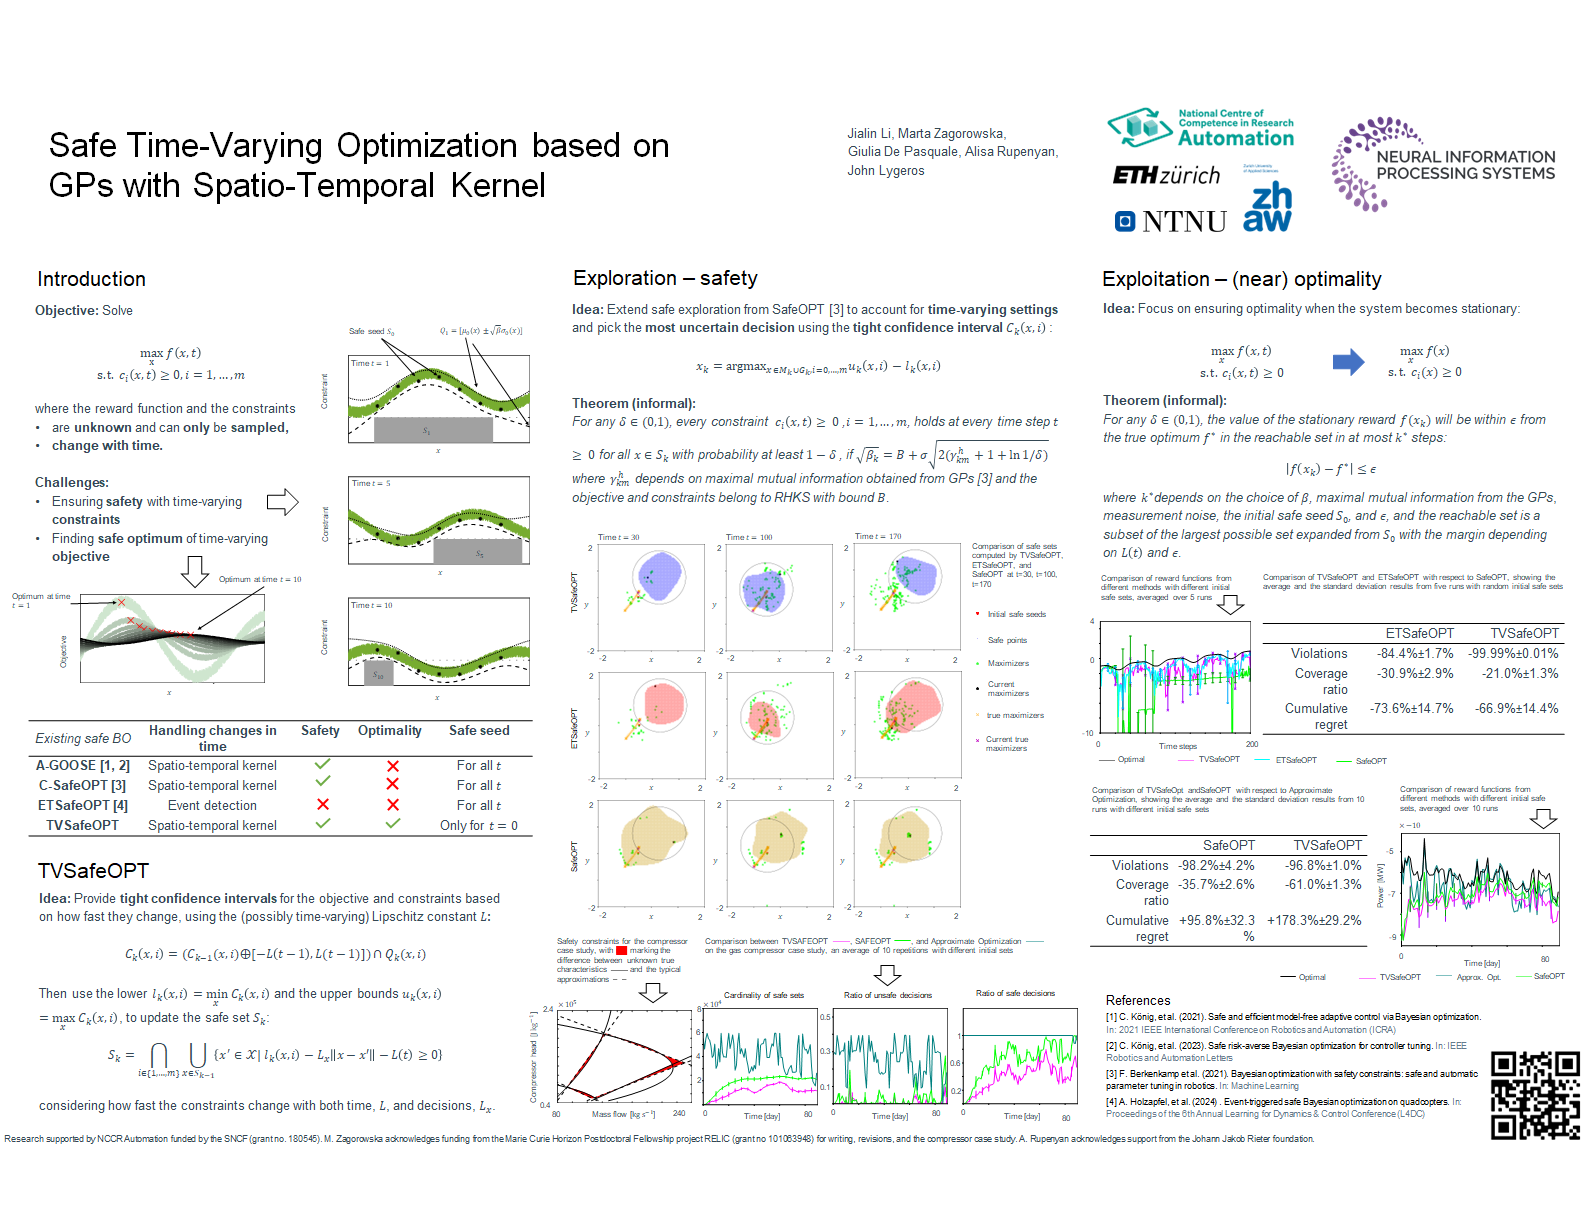
Safe Time-Varying Optimization based on Gaussian Processes with Spatio-Temporal Kernel |
|
"What we want is a machine that can learn from experience." — Alan Turing Based on this website. |